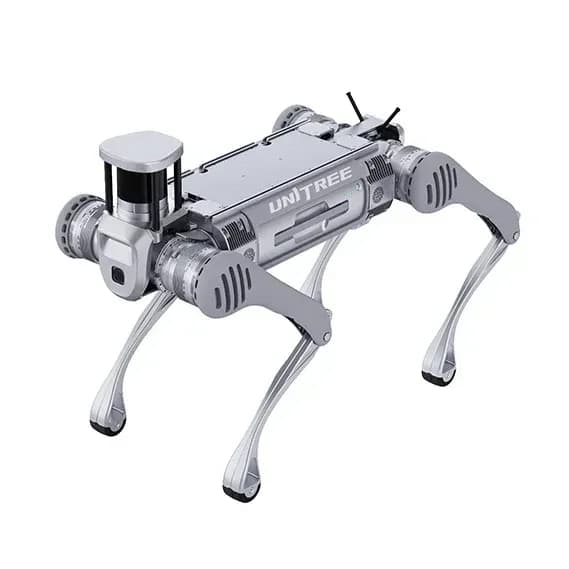
Unitree B2
B2
120kg payload / 6 m/s / 4+ hours
Unitree
G1
A 35kg humanoid with 23 degrees of freedom that folds to 690mm. Bought for locomotion and manipulation research rather than for a job on a production line.
Twenty-three degrees of freedom across legs, waist and arms, in a 1320mm frame that folds to 690mm for transport. The folding matters more than it sounds: a humanoid that fits in a car boot is one a research group can actually take to a demonstration.
The joints are the part worth reading. Industrial crossed roller bearings and low-inertia internal-rotor PMSM motors, with 90N.m at the knee, are specifications from an industrial actuator rather than a hobby platform. That is what separates a research machine from a toy at this price point.
The EDU variant is the one most labs need. It raises knee torque to 120N.m, takes the degree-of-freedom count as high as 43 with optional waist and wrist joints, and adds the Dex3-1 three-fingered hand with force control and optional tactile arrays. Arm payload goes from roughly 2kg to 3kg.
Worth being plain about what this is for. It is a platform for research into locomotion, manipulation and embodied models, not a machine that will do a job unattended. Anyone buying it to perform a task should specify the task first and we will tell them honestly whether this is the right answer.
| Physical | |
|---|---|
| Dimensions | 1320 x 450 x 200 mm standing, 690 x 450 x 300 mm folded |
| Weight | About 35 kg with battery |
Manufacturer-supported options, shown for reference. Contact us to confirm a build.